A closed wedge shell hides high-torque wheel drives, a lithium pack, edge sensing, and a controller laid out for a match. Number 12 won the school competition.
The shape follows the ring. The front is low so it can get under another robot. Sensors look down for the edge and out for an opponent. The drivetrain and battery sit inside the printed scoop.
Front edge sensors and side openings
Arduino-compatible board and motor driver
Two high-torque servos on the wheels
The wiring diagram is the map of the match electronics: battery, converter, controller pins, and the driver.
The diagram routes the battery through a DC-DC converter, breaks out the Arduino pins, and lands the motor signals on a dual-channel driver with PWM, direction, and standby inputs.
Printed scoop with wheel clearance, sensor windows, and a cover over the electronics.
A pair of high-torque digital servos mounted as the wheel drives.
2-cell 2200 mAh lithium pack and a buck converter with a voltage display.
Arduino-compatible board with sensor connectors and a motor-driver stage.
The painted robot, the open chassis, and a driving test from the build.
A recording from the bench and ring tests made while the robot was still being proven, before the school competition.
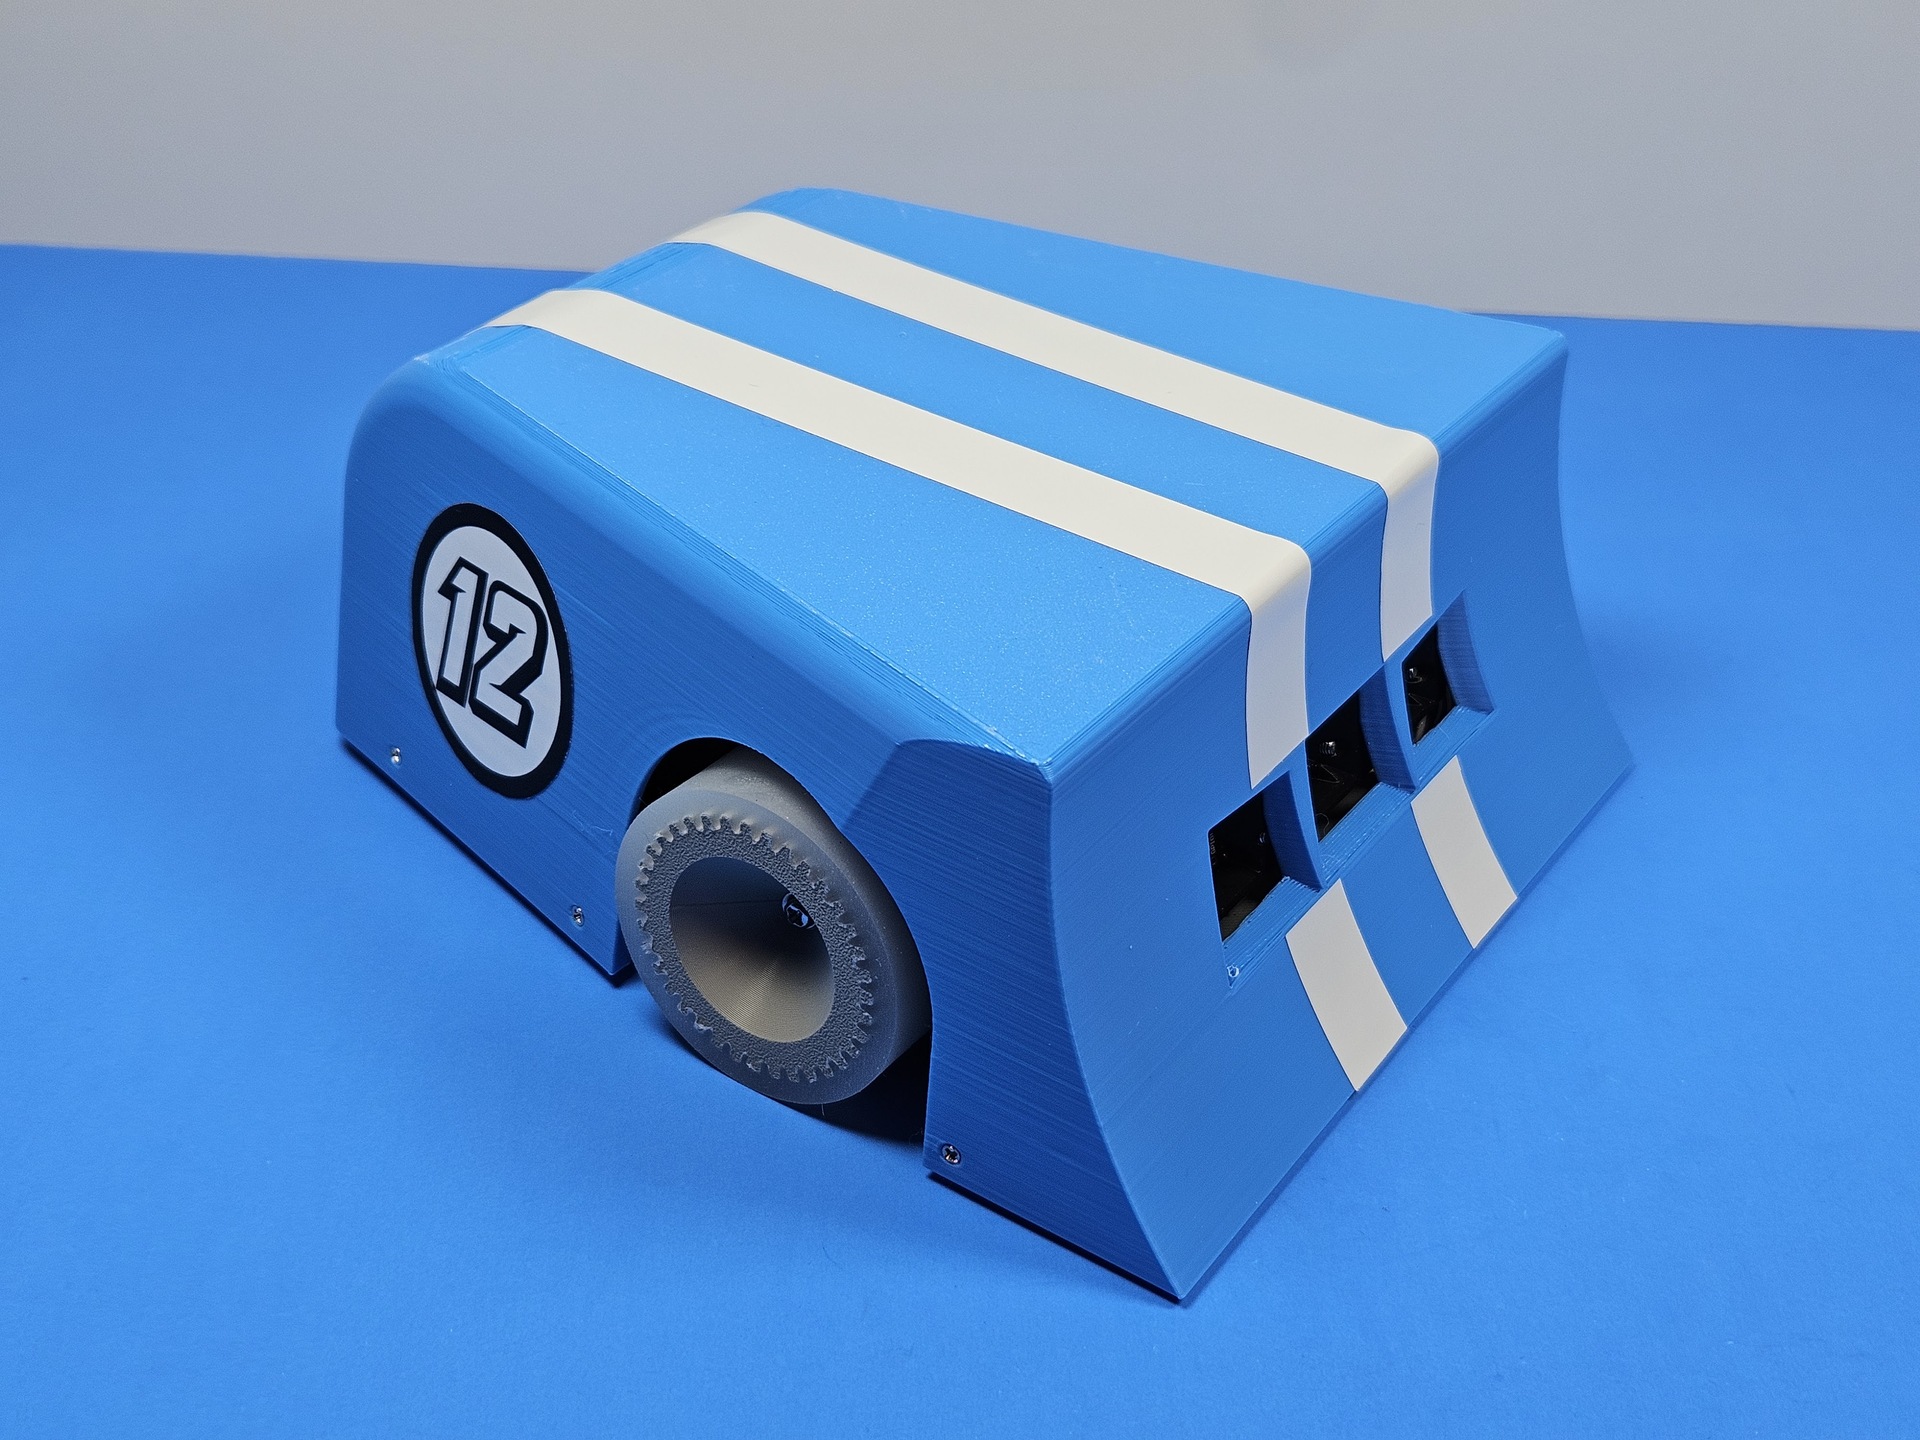
The painted wedge with the roundel, stripes, and front sensor windows.
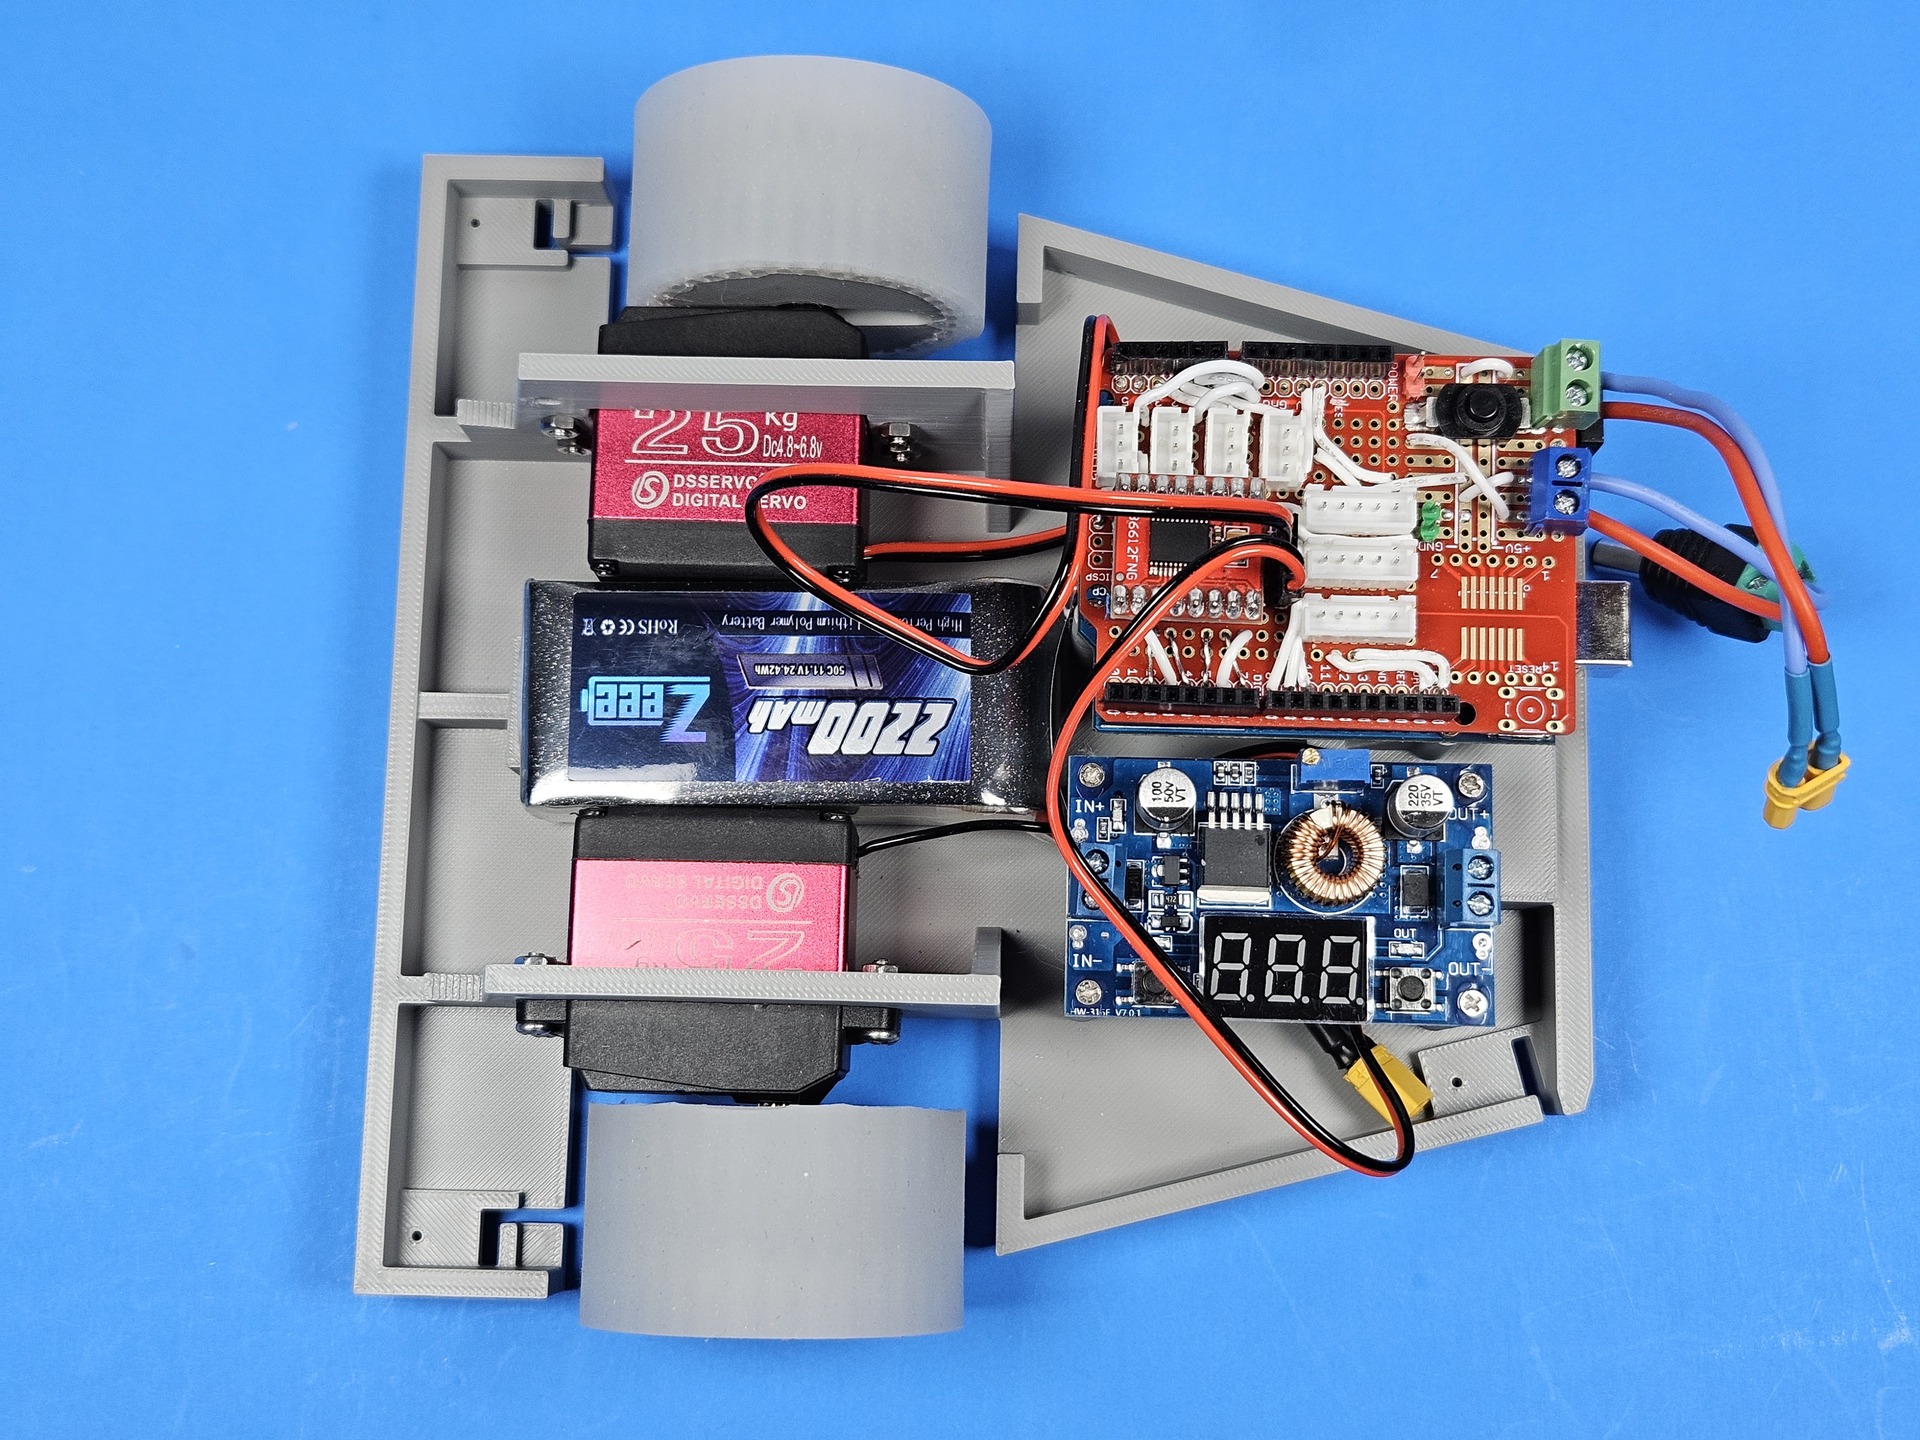
Two digital servos, the 2200 mAh pack, and the converter in the chassis.
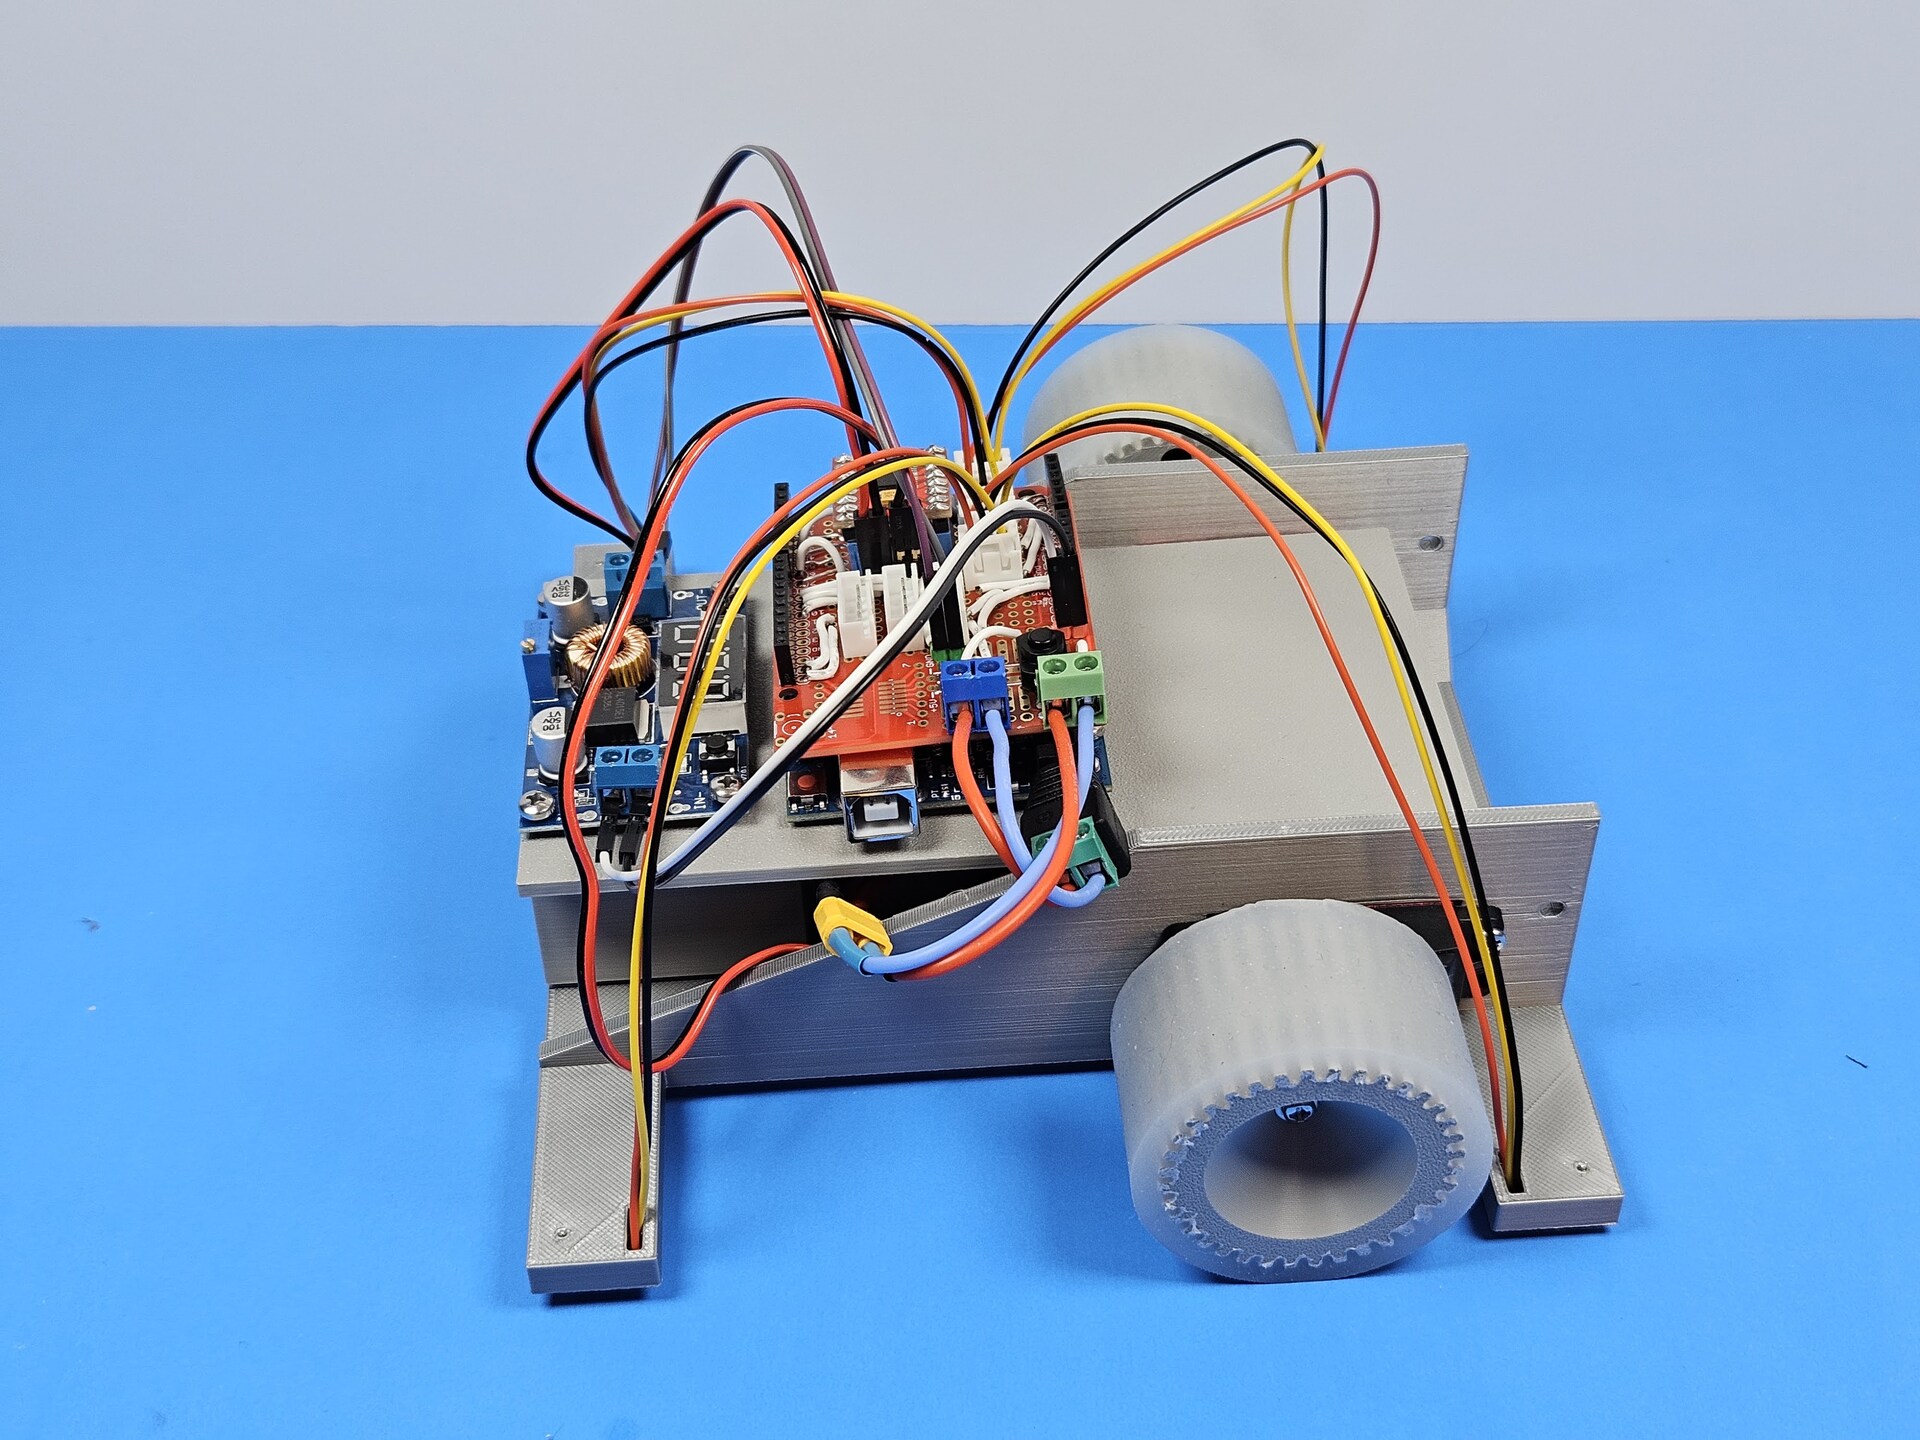
Controller, driver, and sensor leads before the cover went on.
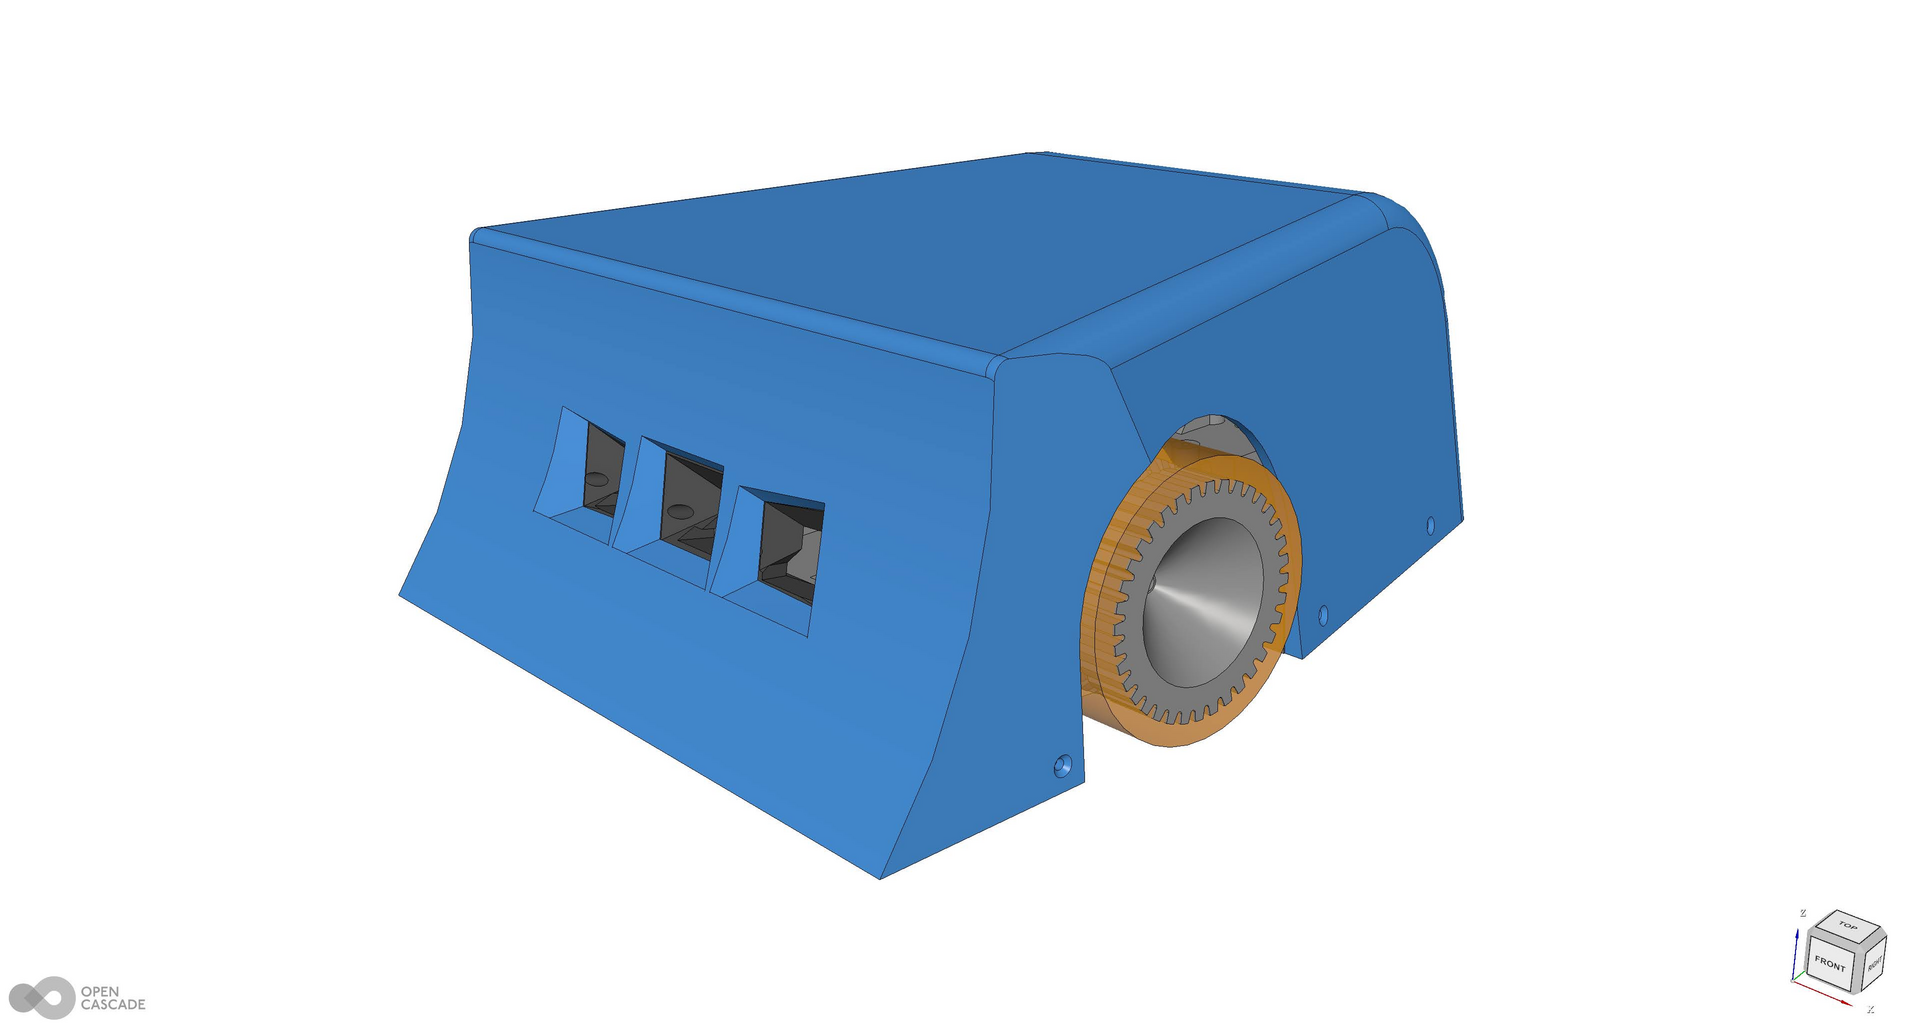
The wedge, wheel, and front sensor windows in the model.
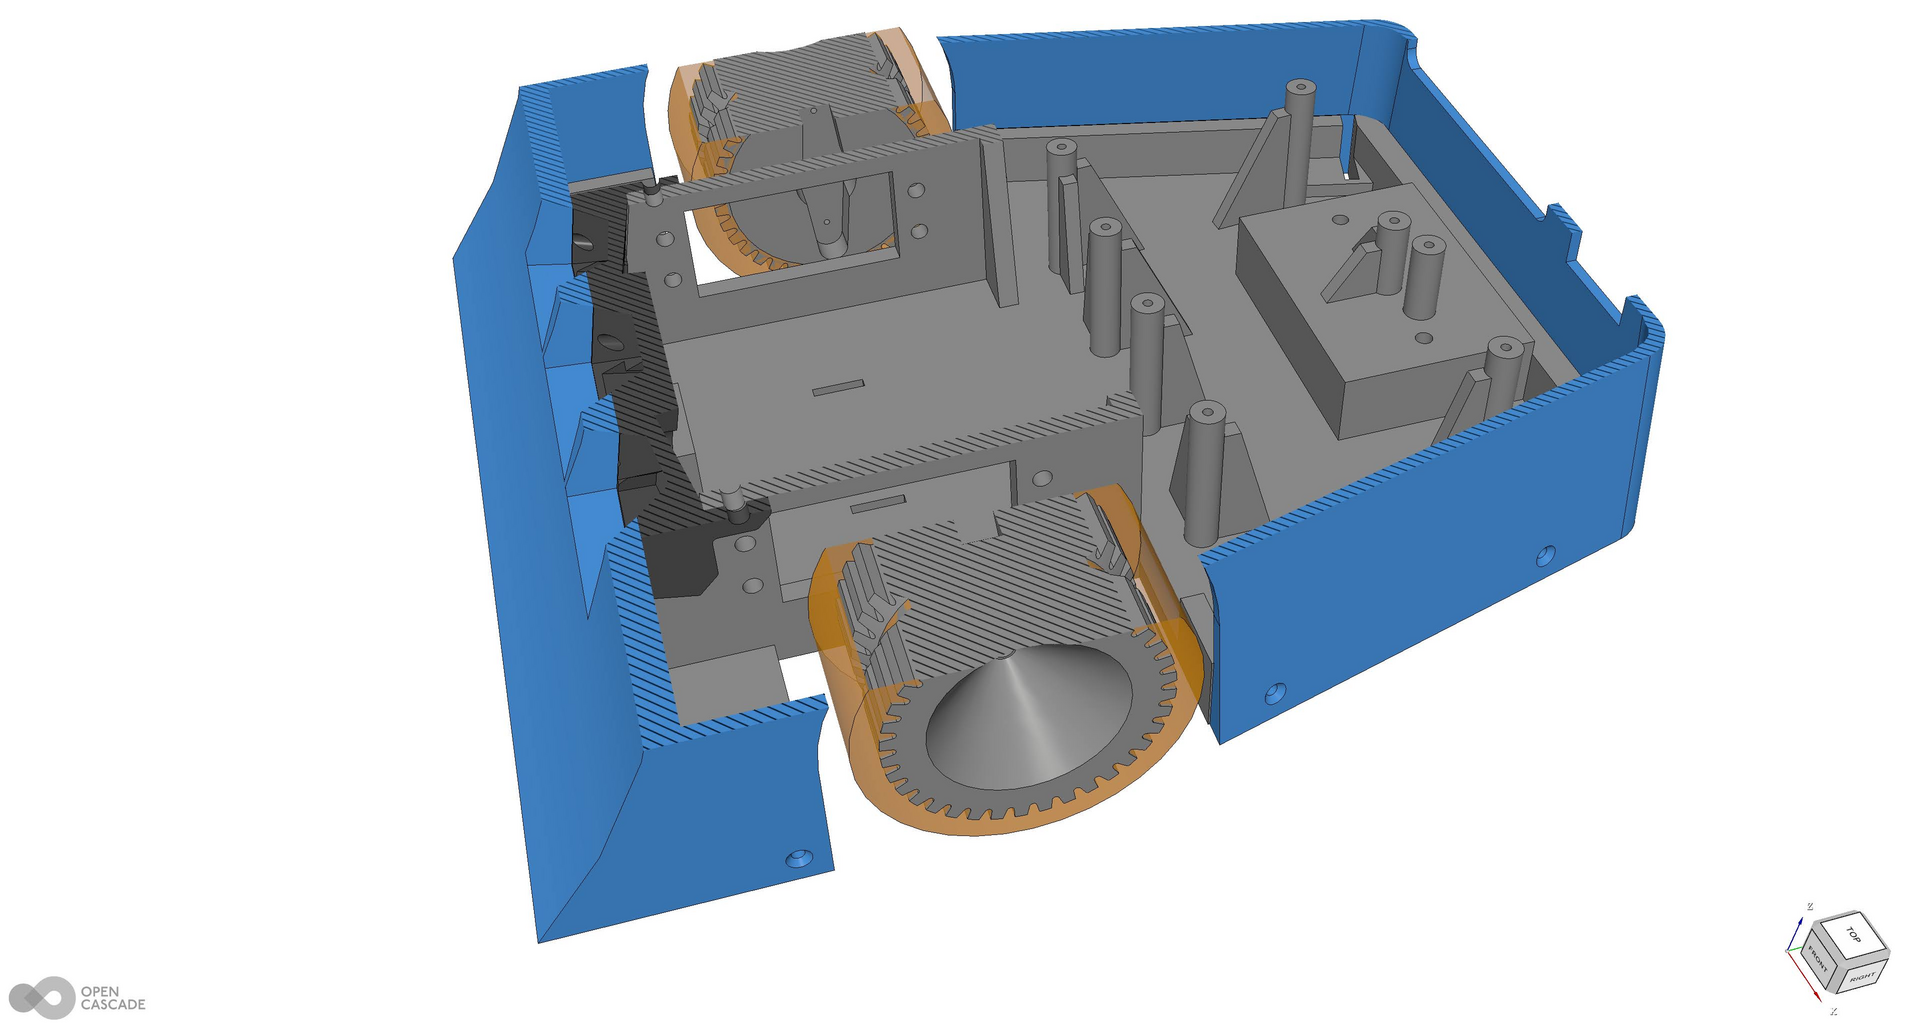
Cutaway of the shell with the wheels and internal structure.
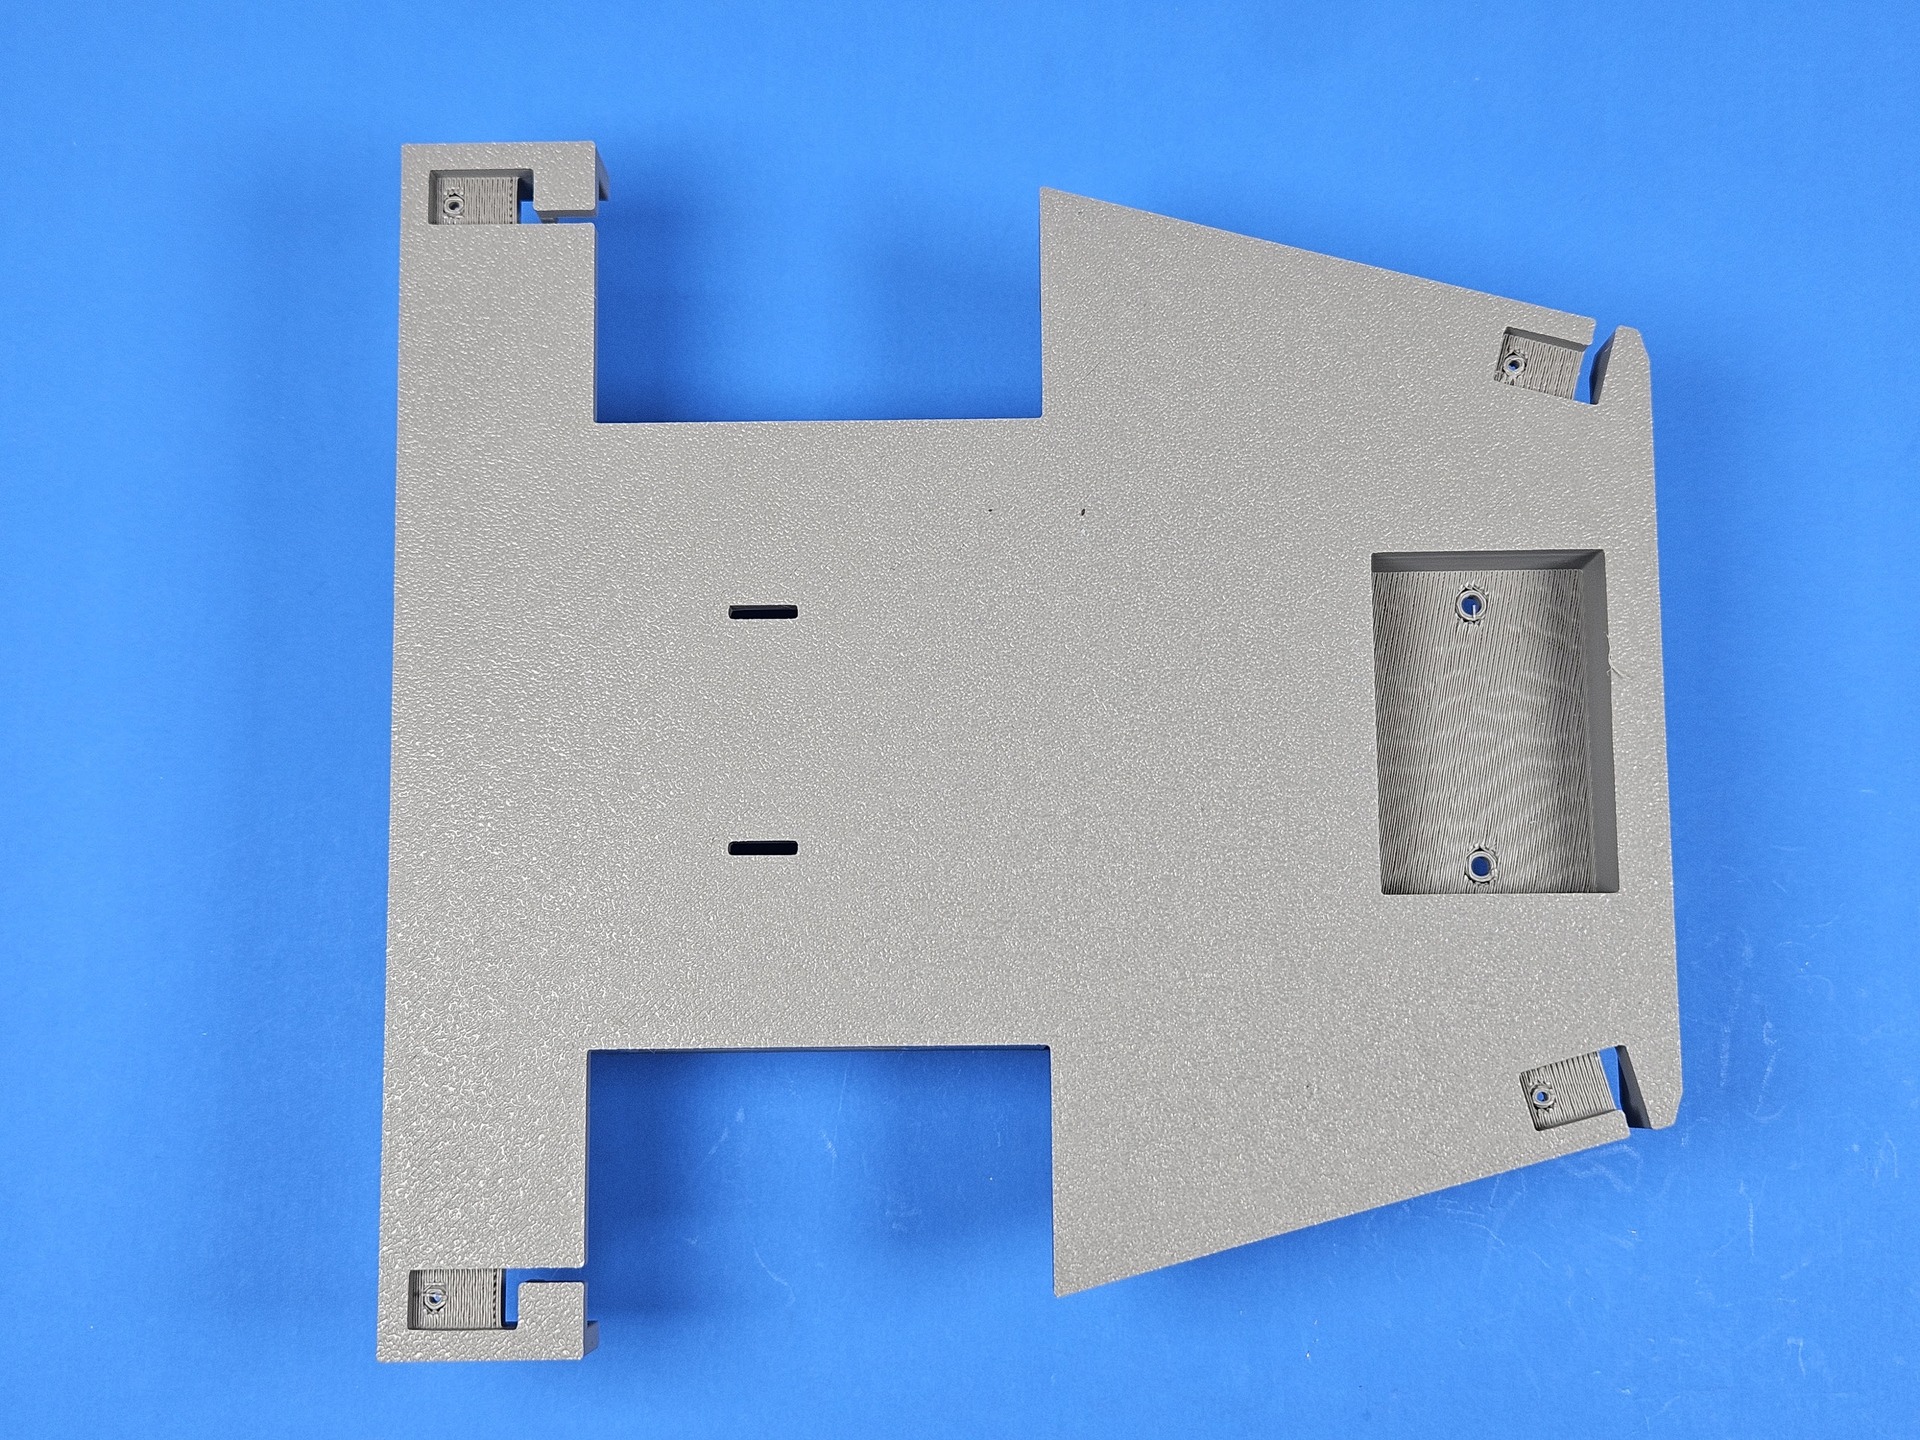
A printed structural plate from the mechanical build.
120 photographs and drawings from this build.
These are the match recordings from the school competition. Robot number 12 won the event.
| PARAMETER | SPECIFICATION / VALUE |
|---|---|
| Class | Mini sumo-style wedge robot |
| Identity | Number 12 |
| Front Sensing | Three low windows for edge sensors |
| Drive | Two high-torque digital servos |
| Battery | 2-cell 2200 mAh lithium pack |
| Logic Power | Buck converter with voltage display |
| Controller | Arduino-compatible board and motor driver |
| Structure | 3D-printed wedge shell and chassis |
| Competition | School sumo event — first place, number 12 |